
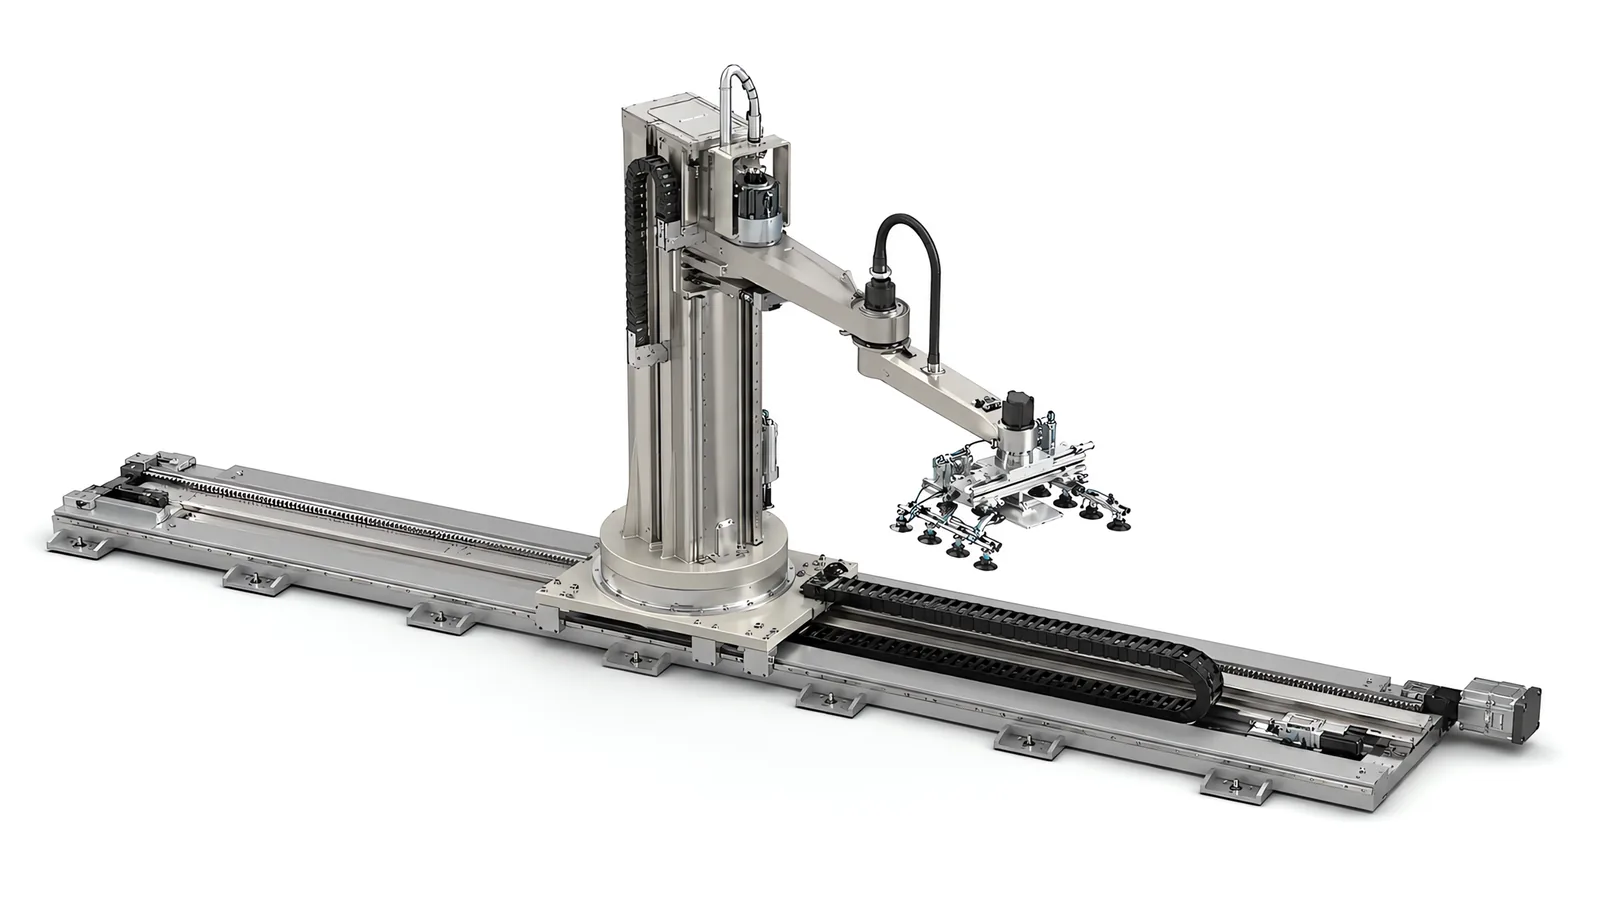
Why Did the Seventh Axis Have to Be 100 mm Tall?
Motionwell Automation designed and built an ultra low profile robot seventh axis linear track, 100 mm in overall height, carrying a six-axis arm across 1.5 m or more of stroke on a 3 m track at up to 500 mm/s, repeat positioning to plus or minus 0.5 mm on a ground-grade rack and pinion, with a slide platform load of 1.5 tonnes. It bolts directly onto the factory floor.
The reason to put an arm on a rail at all is spread. Either the part is longer than the robot’s reach, or one robot has to serve several stations that will not fit inside a single working envelope. A track answers both because it moves the whole arm: every point along the stroke is served by the same reach, the same payload curve and the same tooling. What it does not do is add payload. An arm that cannot lift the part at full extension still cannot lift it after you have put it on a rail.
That much is ordinary, and it is set out in full on our robot seventh axis and linear track page. The constraint that shaped this particular build was vertical. A track sits between the floor and the robot base, so the arm’s entire working envelope rises by the height of the track, and that height comes out of the process end. A conventional robot travel unit takes 200 to 400 mm of vertical working height before the arm has done anything, which is why tracks in this payload class are often dropped into a sunken floor pit to win the height back.
Where the loss bites is not obvious from a datasheet, and it is worth checking in three directions. Reaching down: can the wrist still get to the bottom of a tote, a machine table or the infeed conveyor, or has the base risen far enough that it bottoms out. Reaching up: raising the base helps the top of a stack and hurts ceiling clearance, and it is the arm at full extension that finds the sprinkler line. Reaching in: a machine tool door or a chamber opening sits at a fixed height, and a pedestal of that height can turn a straight entry into an approach angle the wrist cannot hold.
| Conventional travel unit | This track | |
|---|---|---|
| Overall height above floor | 200 to 400 mm | 100 mm |
| Effect on the arm’s envelope | Whole envelope rises by the track height | Same effect, but 100 mm of it |
| Floor preparation | Often a sunken pit to recover the lost height | Bolts to the slab on adjustable feet |
| What the pit brings with it | Civil works, drainage, a permanent hole in the floor plan, a cleaning problem in a clean or washdown environment | None of it |
What Is in the Delivered Track?
| Parameter | Delivered figure |
|---|---|
| Overall track height | 100 mm |
| Stroke | 1.5 m or more, on a 3 m track |
| Maximum travel speed | 500 mm/s |
| Repeat positioning | +/-0.5 mm |
| Slide platform load | 1.5 tonnes |
| Drive | Servo motor, planetary gearbox, ground-grade rack and pinion |
| Guidance | Dual linear ball bearing rails |
| Levelling | Six adjustable feet |
| Robot | Six-axis arm, run as a coordinated external axis of the robot controller |
The carriage is a machined mounting plate with dowel-pin location, so the arm returns to a known position on the platform after it has been lifted off. Guidance is two rails, which is what carries the overturning moment an arm generates when it works at extension off the side of the carriage.
Services travel with the robot in an energy chain running the length of the stroke, under a protective cover, with power, signal and air routed in one managed run. Cable specification is the part that decides whether that installation survives: continuous-flex cable rated for the travel, bend radius respected at design time, and chain fill sized so cables move. A jacket cracked at a tight bend fails in the middle of the stroke, where it is least accessible, and it reappears every time it is patched. Travel is also protected independently of software by end-of-travel limit switches on the axis, so an overrun is caught by hardware, never by a parameter somebody can edit.
Why Is the Drive a Ground Rack and Pinion?
Because of what is riding on it. A robot on a carriage is a large mass with a moving centre of gravity, and it feeds reaction torque back into the axis every time the arm accelerates. That is a stiffness problem. A drive whose compliance changes as the carriage travels gives you an axis that settles differently at each station, and settling time is a cost you only meet once the cell is running.
| Drive | Behaviour over long travel | Stiffness under a moving robot |
|---|---|---|
| Rack and pinion | Length is added by joining sections, and is not fixed by the drive element | High, and constant along the stroke, because engagement is local |
| Toothed belt | A single span, so compliance grows with length and the natural frequency falls | The spring between motor and load lengthens as the carriage travels |
| Ballscrew | Length limited by whip and critical speed, so long strokes force a larger screw and a lower speed | Very high on short strokes, which is why it belongs on Z axes and stages |
Two consequences of that choice belong in any specification written around this axis. Backlash at the pinion mesh is dealt with mechanically at build time, because the mesh carries the load and it cannot be tuned out in software afterwards. And a rack and pinion axis is open by design, since the pinion has to engage the rack and the bearing blocks have to engage the rails, so protection is about keeping contamination off the engagement, and never sealing it away inside a tube. The same drive logic runs through the rest of our linear work, compared side by side on the servo lift and linear positioning page.
What Does the +/-0.5 mm Figure Actually Tell You?
Less than a specification writer usually wants it to. Repeatability describes how tightly the axis returns to a position it has already been taught, and +/-0.5 mm on this track is that measurement, taken through the rack and pinion drive with encoder feedback. It is a track figure: the six-axis arm riding on it holds a much tighter repeatability at the wrist, and the track exists to deliver the arm to the station, where the arm does the fine positioning. Accuracy is a different claim again: how close the axis gets to a coordinate it has been commanded to, anywhere along the stroke. On the column palletizing track we quote +/-0.5 mm positioning along the rail from an absolute linear encoder, which is a positioning figure. Two suppliers quoting different measurements look like a price difference until somebody checks which number was being quoted.
Then the harder point, which applies to every machine we build and is argued in full on our mechanical design and simulation page: none of those figures is placement accuracy on your part. The axis says nothing about gripper slip, part tolerance, fixture wear or thermal drift, and thermal growth is the one a long axis adds by itself, because it accumulates with length in a hall whose temperature moves between the night shift and the afternoon. The working answer is to teach positions at each station, and to derive nothing from a nominal track coordinate.
How Does the Track Run as the Robot’s External Axis?
It is driven by the robot controller. The controller treats the track as a coordinated external axis, which is a controller capability and is worth confirming against the arm you intend to buy before the track is quoted. Treated that way, the track servo hangs off the robot controller, the track appears in the same motion planner and the same coordinate frame as the arm, and the transit is planned together with the arm’s own motion instead of in series with it.
| Coordinated external axis | Track as an independent PLC servo axis | |
|---|---|---|
| Motion planning | Track and arm planned together, so moves overlap | Move, wait, confirm, move: the arm waits for the carriage to stop |
| Coordinate frames | One frame, and a taught position includes the track position | Two frames, taught and maintained per station |
| Programming | The robot program owns the whole motion | Robot program, PLC axis program, and an interface between them |
| Recovery after a fault | One controller knows where the arm and the carriage both are | Recovery logic reconstructs a state split across two machines |
| Offline simulation | Reach and cycle verified across the full stroke before anything is built | Simulation covers the arm; the transit is a spreadsheet estimate |
None of that makes the PLC route wrong everywhere. A track that parks at three fixed stations with a long dwell at each one works perfectly well as an indexed axis, and the end-of-line palletizing cell is close to that pattern. The moment transit has to hide inside the arm’s own motion, the coordinated axis is what makes it possible at all.
What Did the Installation Ask of the Floor?
The civil scope was six adjustable feet and a levelling exercise. That is cheap compared with excavation, and it is the reason the 100 mm height is worth engineering for, but it is not nothing.
A track is a straightedge bolted onto a surface that is not straight, so levelling and shimming is what converts a good axis into a good installation. Flatness and level are measured along the whole run, and the run is levelled as a whole, because correcting one foot moves its neighbours. Anchoring is the second half of it. The anchors do not only carry the static weight of the arm and the carriage; they take the reaction every time the arm accelerates and every time a 1.5 tonne platform load decelerates on top of them, and those are horizontal loads into the slab as well as vertical ones. Distributed load along the track and point loads at the feet both get checked against the slab, particularly on an upper floor.
The last practical item is the route in. The track arrives in sections that have to reach the installation position through the doors and aisles that actually exist, which is what decides how the frame is split, and not any preference for fewer joints.
How Does a Moving Robot Base Change the Safety Case?
The safeguarded space grows with the stroke. A fixed arm has one safeguarded area; an arm on a rail has one as long as the rail, plus the crushing and shearing hazards of the carriage and the track itself, which exist whether or not the arm is moving. The gap between the moving carriage and anything fixed beside it is a trapping point that travels along the run, and it is designed out with clearance and covers at concept stage or guarded around forever afterwards.
The method does not change. A risk assessment sets the limits of the machine and covers every mode, including teaching and fault clearing, when guards get opened and hands go where the designer never pictured them. The robot and the integrated system are covered by ISO 10218-1:2025, with each safety function rated for performance level under ISO 13849-1. One track-specific point is worth stating plainly: stopping performance now includes up to 1.5 tonnes of travelling mass, so the distances that set scanner and fence positions have to be measured on the built machine, and never calculated from the arm alone. That scope, and the LVD and CE testing around it, is described on our machine safety and compliance page.
Which Five Decisions Shaped This Track, and What Did Each Cost?
Distance. The track moves the arm; it does not raise the payload curve. If the arm is marginal on the part at reach, it is marginal at every point along the stroke, and the answer is a different arm.
Availability across shared stations. One robot and track share their availability across the stations they serve. The layout review therefore includes fault recovery, buffer capacity and maintenance access. Independent robot cells are another option where each station needs to continue producing during work on its neighbour.
A traverse on every cycle buys a slower cell. A track pays for itself when the transit hides inside a wait that already exists. If the robot has to run the full stroke every single cycle, transit time has been added to every cycle.
Reach is checked for the complete robot and track. The track adds linear travel while the arm retains its joint motion, so stations on either side may be reachable. A layout study checks each approach, tool orientation, collision envelope and access route. Where floor access drives the design, compare an overhead beam using the gantry versus six-axis machine tending guide.
Compare the complete installed travel unit. Stroke, load, installed height and controller compatibility determine whether a standard or custom track best fits the cell. This design addresses the low-height requirement with a 100 mm overall section and direct floor mounting.
Where Else Does This Engineering Show Up?
The heavy end of the same engineering, where the moving mass changes the problem in kind, is on our heavy duty robot track page, and the precision work this track class supports is described under aerospace and precision engineering. Loading and unloading machine tools with an arm on a rail is covered under machine tending automation, and the wider cell scope around any arm sits with robot integration services.